ABOUT ME
Hi, I am Yuechen Luo, a master's student at the School of Vehicle and Mobility, Tsinghua University, and a research intern at Xiaomi EV.
My research focuses on vision-language-action models, reinforcement learning, world models, and end-to-end autonomous driving. I am especially interested in reasoning, verification, and robust policy learning for long-tail driving scenarios.
LATEST
News
Xiaomi OneVL has been accepted to NeurIPS 2026.
LaST-VLA has been accepted to NeurIPS 2026.
BACKGROUND
Education
Tsinghua University
2024 — PresentM.S. Student · School of Vehicle and Mobility
Harbin Institute of Technology
2020 — 2024Bachelor's Degree · School of Transportation
RESEARCH
Selected Publications
Selected work on autonomous driving and embodied intelligence. * denotes equal contribution.
 Xiaomi Technical Report
 · Cross-Embodiment Learning
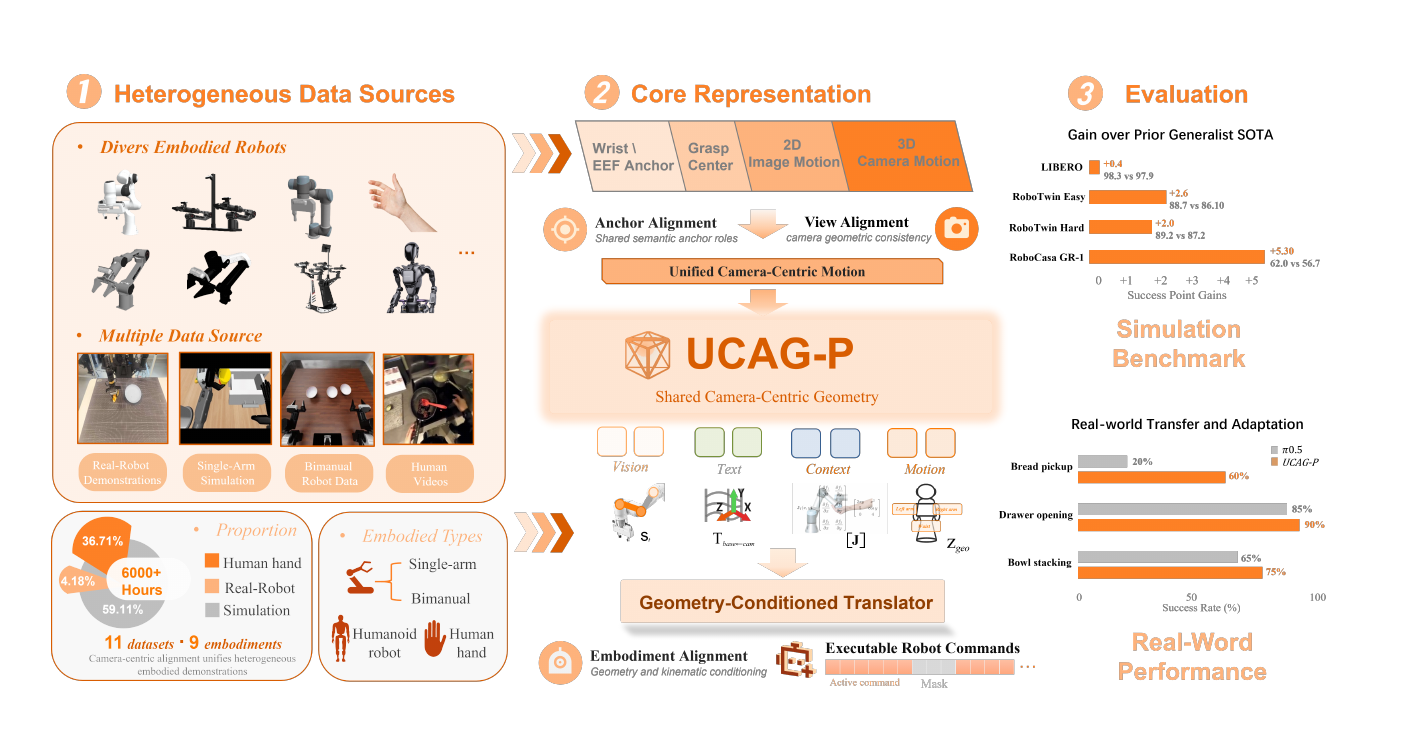
One Policy, Many Embodiments: Unified Camera-Centric Action Geometry Pre-training for Heterogeneous Embodied Manipulation
UCAG-P aligns heterogeneous robot and human demonstrations in a shared camera-centric action space for transferable manipulation.
 ECCV 2026
CCF B
World Models · Online Correction
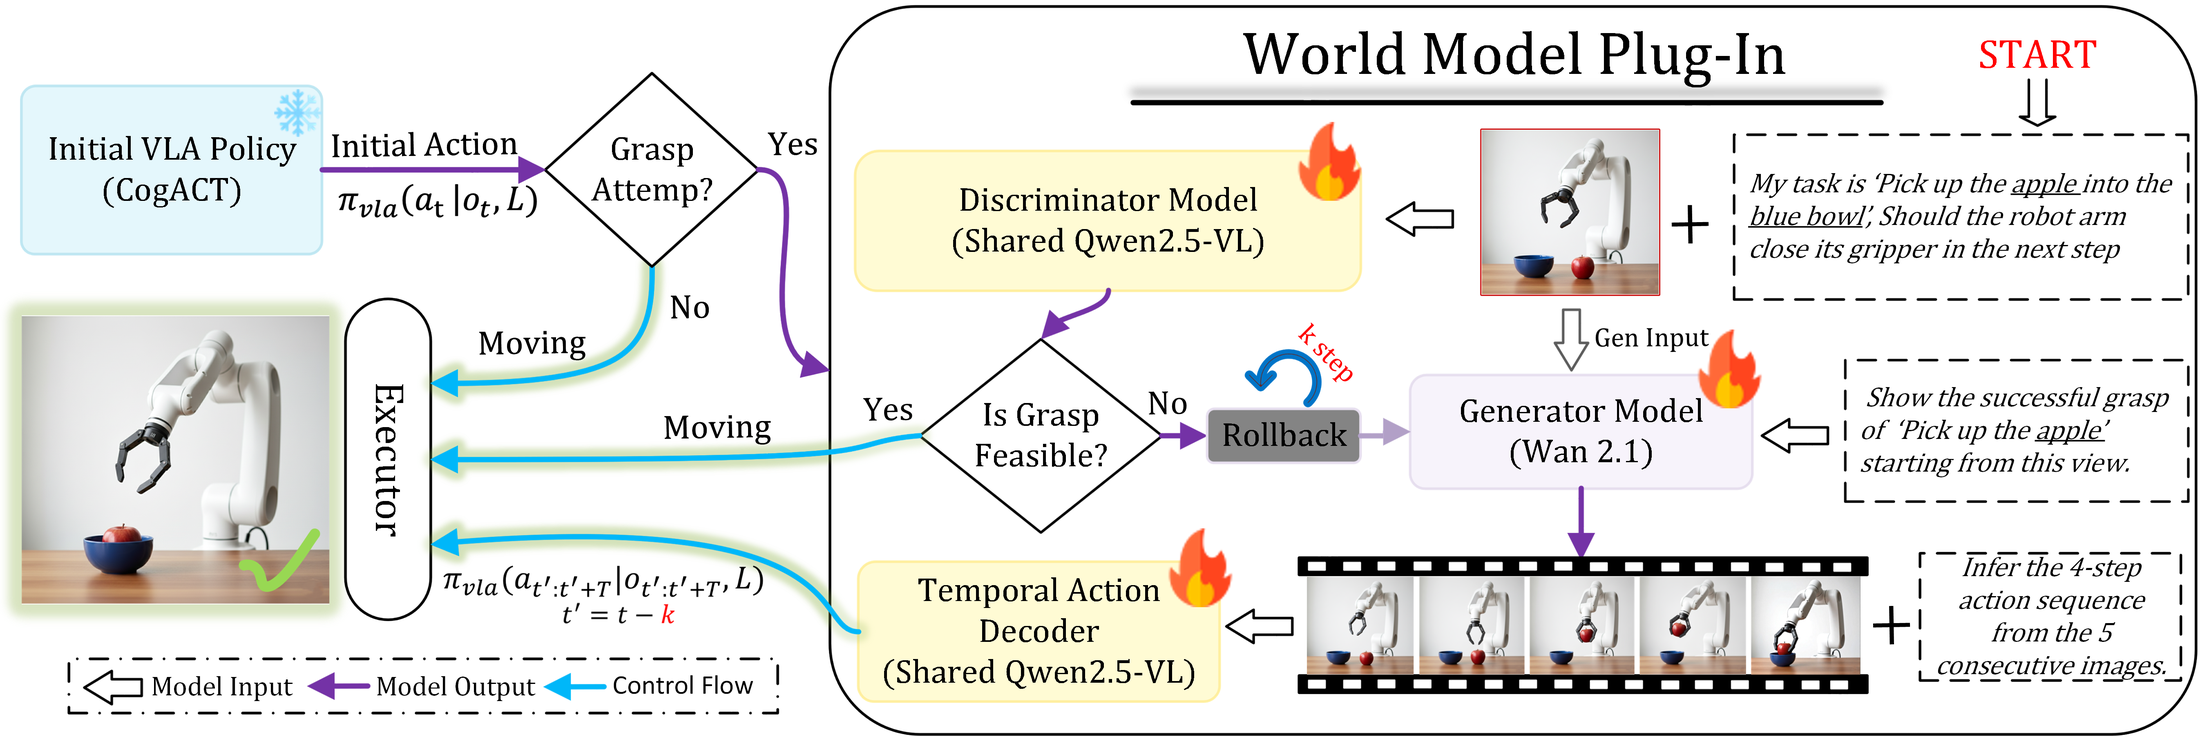
World-in-Loop: Online Correction via Event-Triggered World Models for Robust VLA Policies
An event-triggered world model detects risky grasp attempts and imagines successful futures to correct VLA policies online.
 IROS 2026
CCF C
Test-Time Verification · Planning
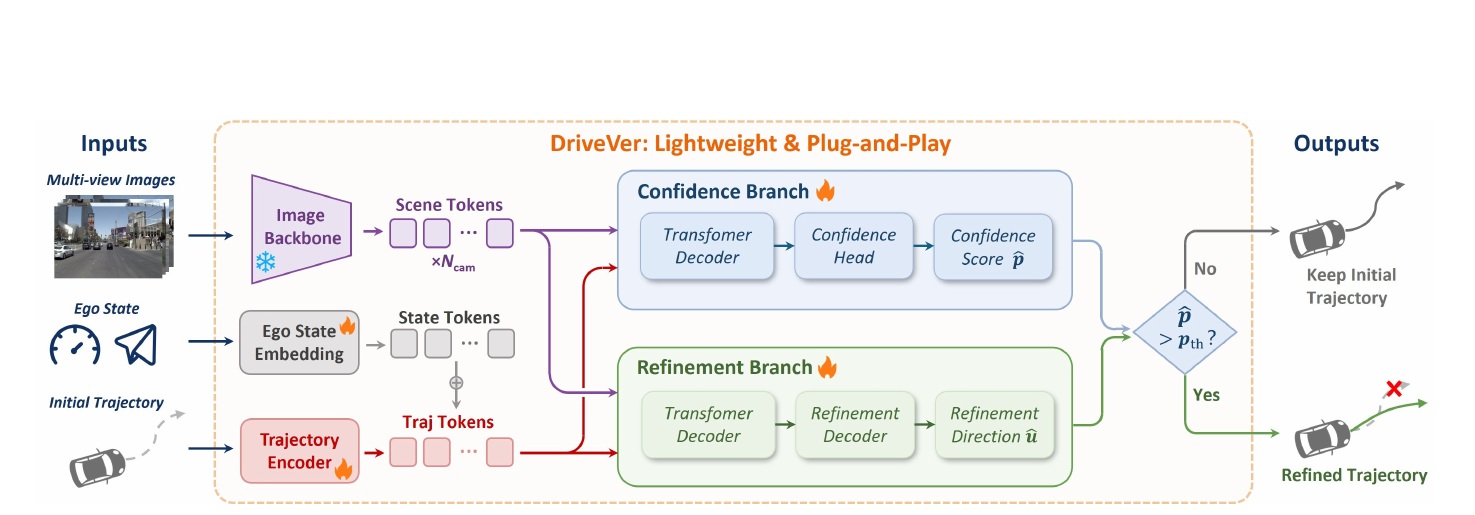
DriveVer: Lightweight Trajectory Evaluator as Test-Time Verifier for Autonomous Driving
A compact plug-and-play verifier scores and refines candidate trajectories at test time with minimal latency overhead.
 arXiv 2026
Reward Modeling · Driving Dataset
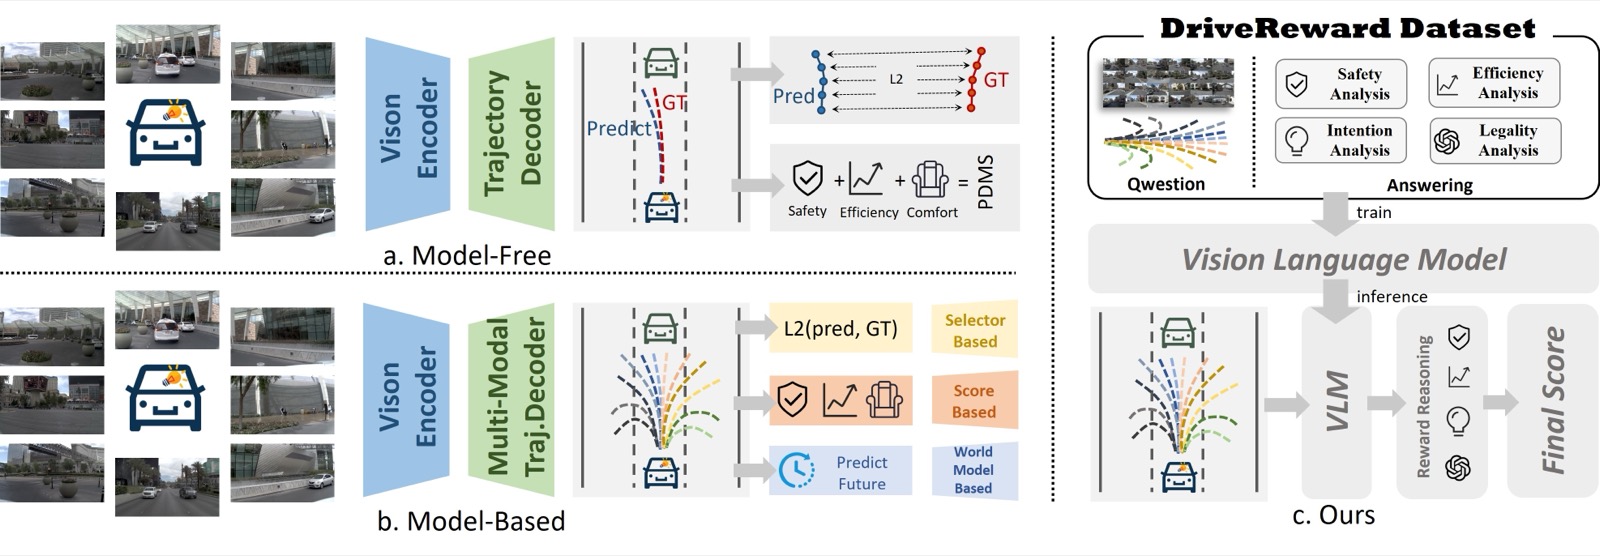
DriveReward: A Comprehensive Dataset and Generative Vision-Language Reward Model for Autonomous Driving
DriveReward introduces a counterfactual driving dataset and a compact generative reward model for trajectory evaluation and RL.
 NeurIPS 2026
CCF A
Latent Reasoning · World Models
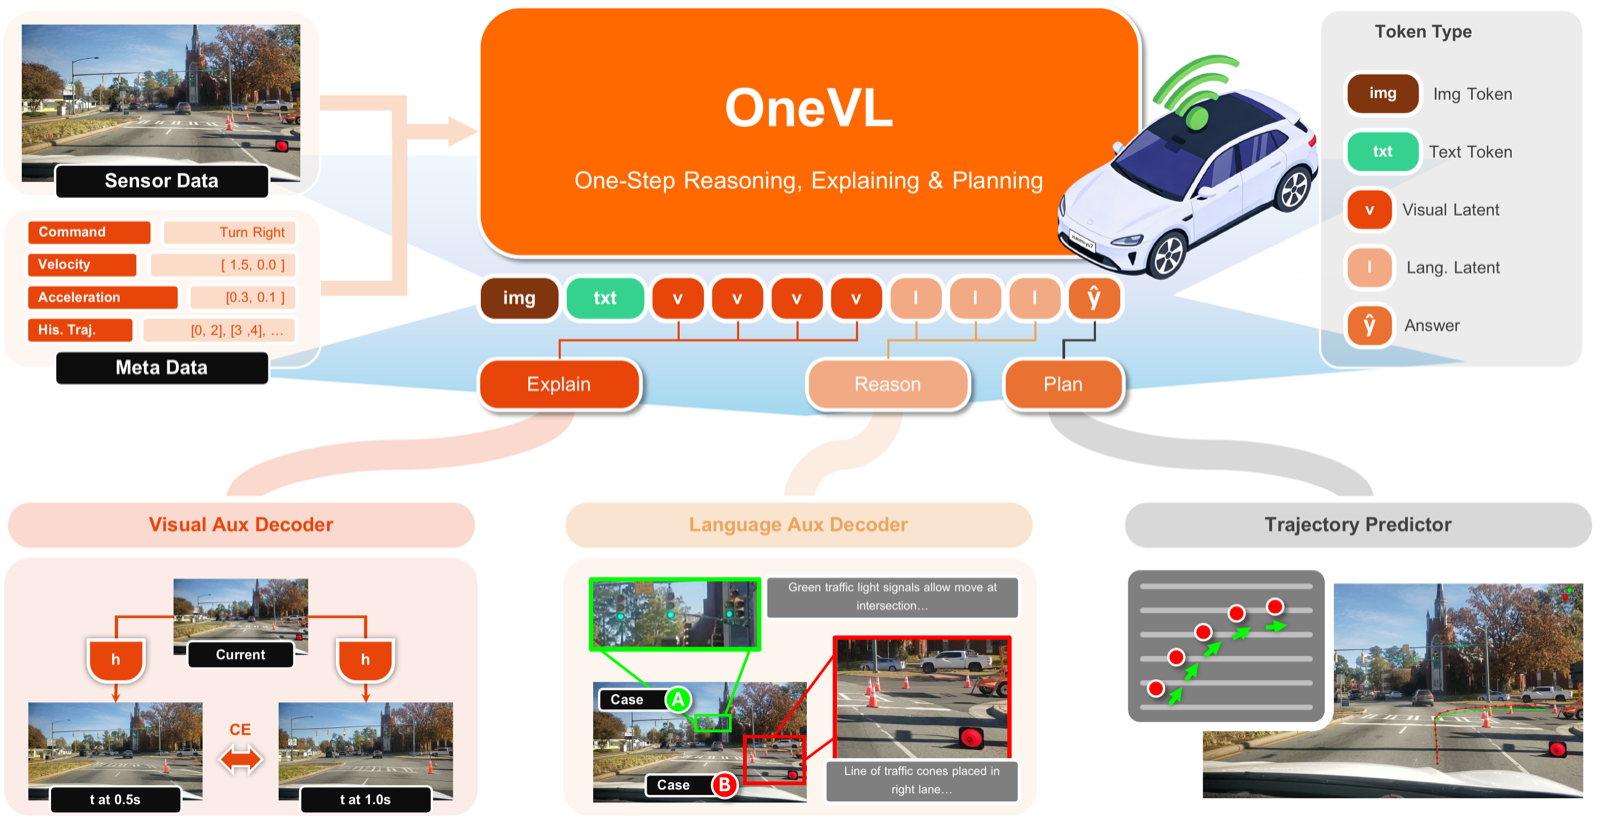
Xiaomi OneVL: One-Step Latent Reasoning and Planning with Vision-Language Explanation
OneVL compresses visual prediction and language reasoning into latent tokens for fast, interpretable planning.
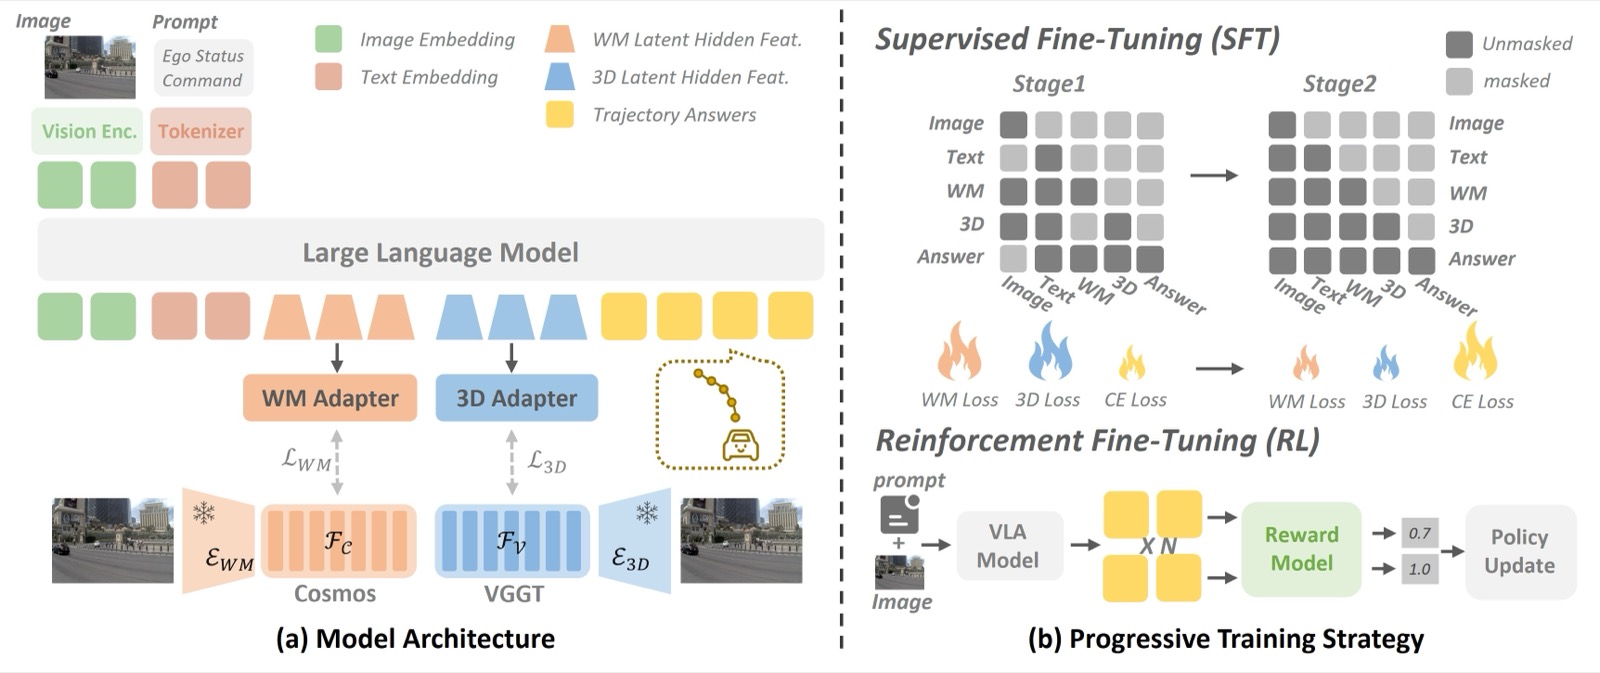 NeurIPS 2026
CCF A
Latent Reasoning · Autonomous Driving
LaST-VLA: Thinking in Latent Spatio-Temporal Space for Vision-Language-Action in Autonomous Driving
LaST-VLA grounds latent reasoning with geometric constraints from 3D models and dynamic foresight from world models.
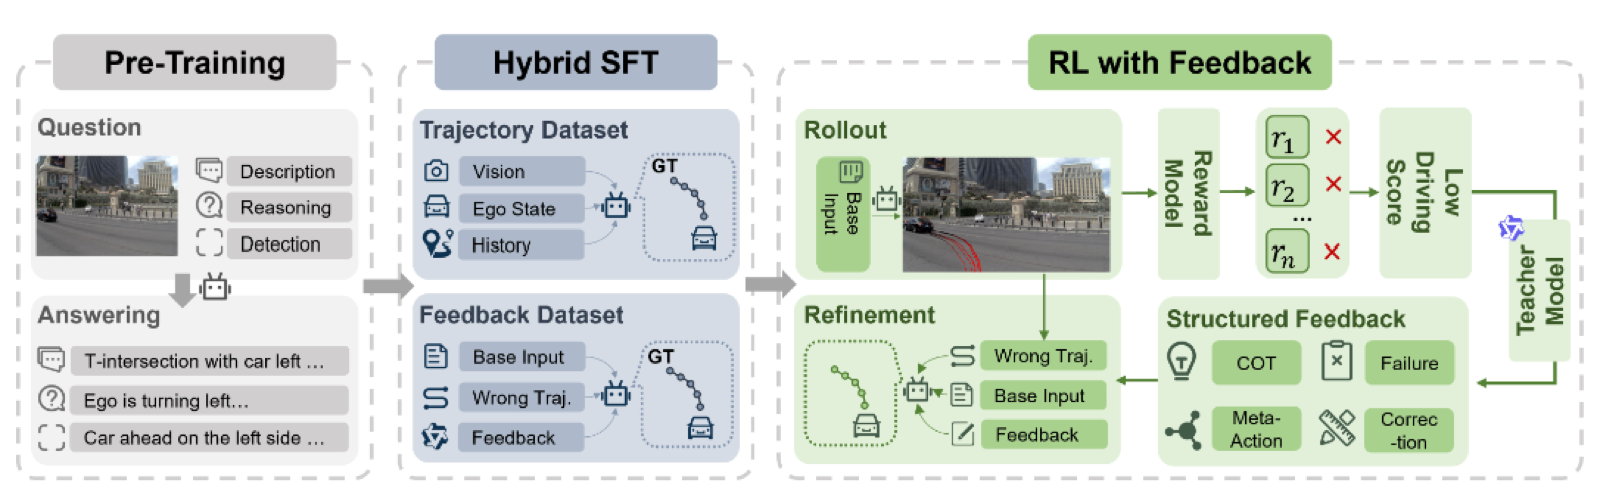 CVPR 2026
CCF A
Reinforcement Learning · Failure Feedback
Unleashing VLA Potentials in Autonomous Driving via Explicit Learning from Failures
ELF-VLA turns persistent RL failures into structured feedback and high-value corrective rollouts.
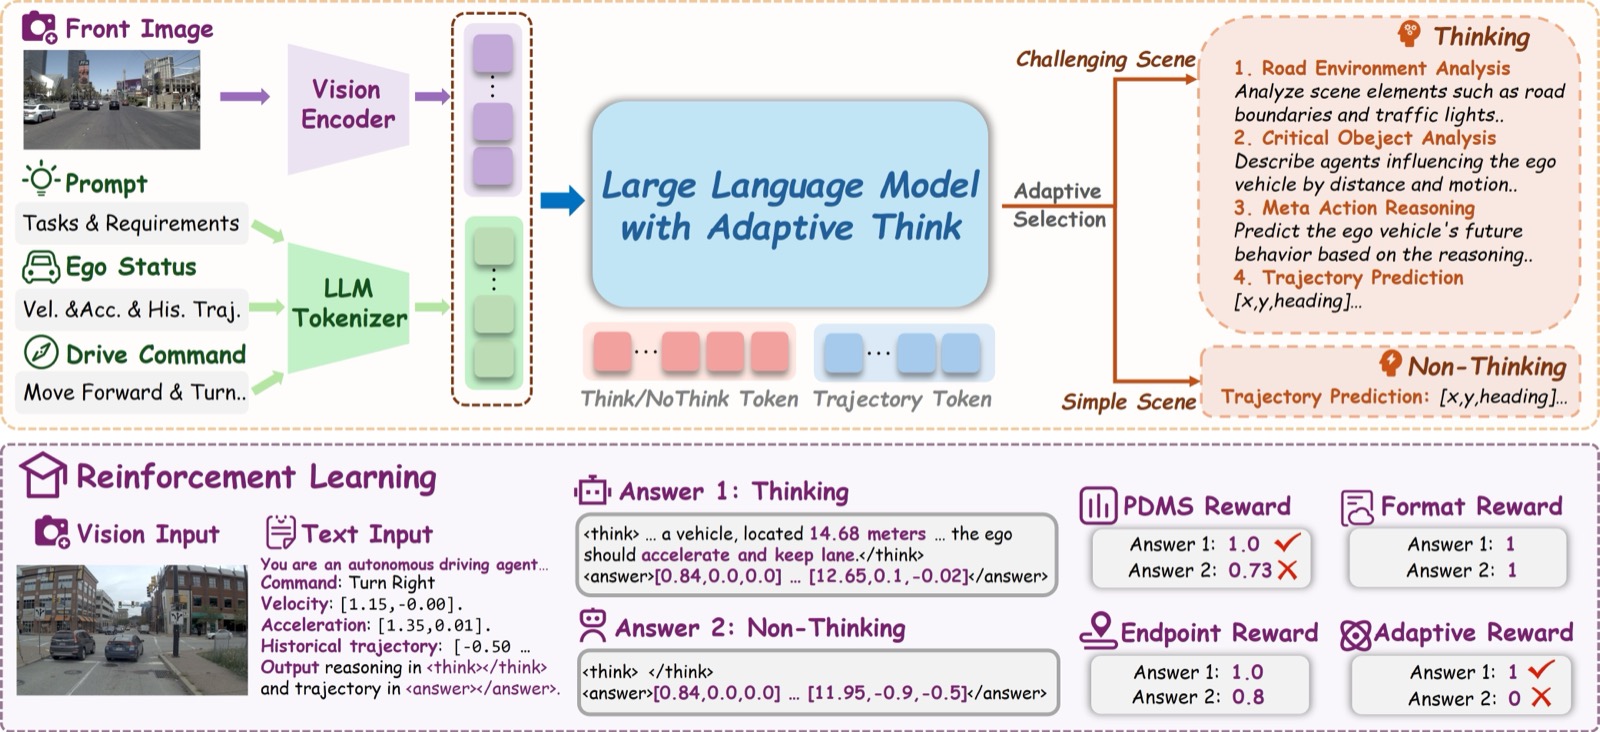 ICRA 2026
CCF B
Adaptive Reasoning · Reinforcement Learning
AdaThinkDrive: Adaptive Thinking via Reinforcement Learning for Autonomous Driving
AdaThinkDrive learns when to reason and when to act directly, reducing unnecessary chain-of-thought in simple scenes.
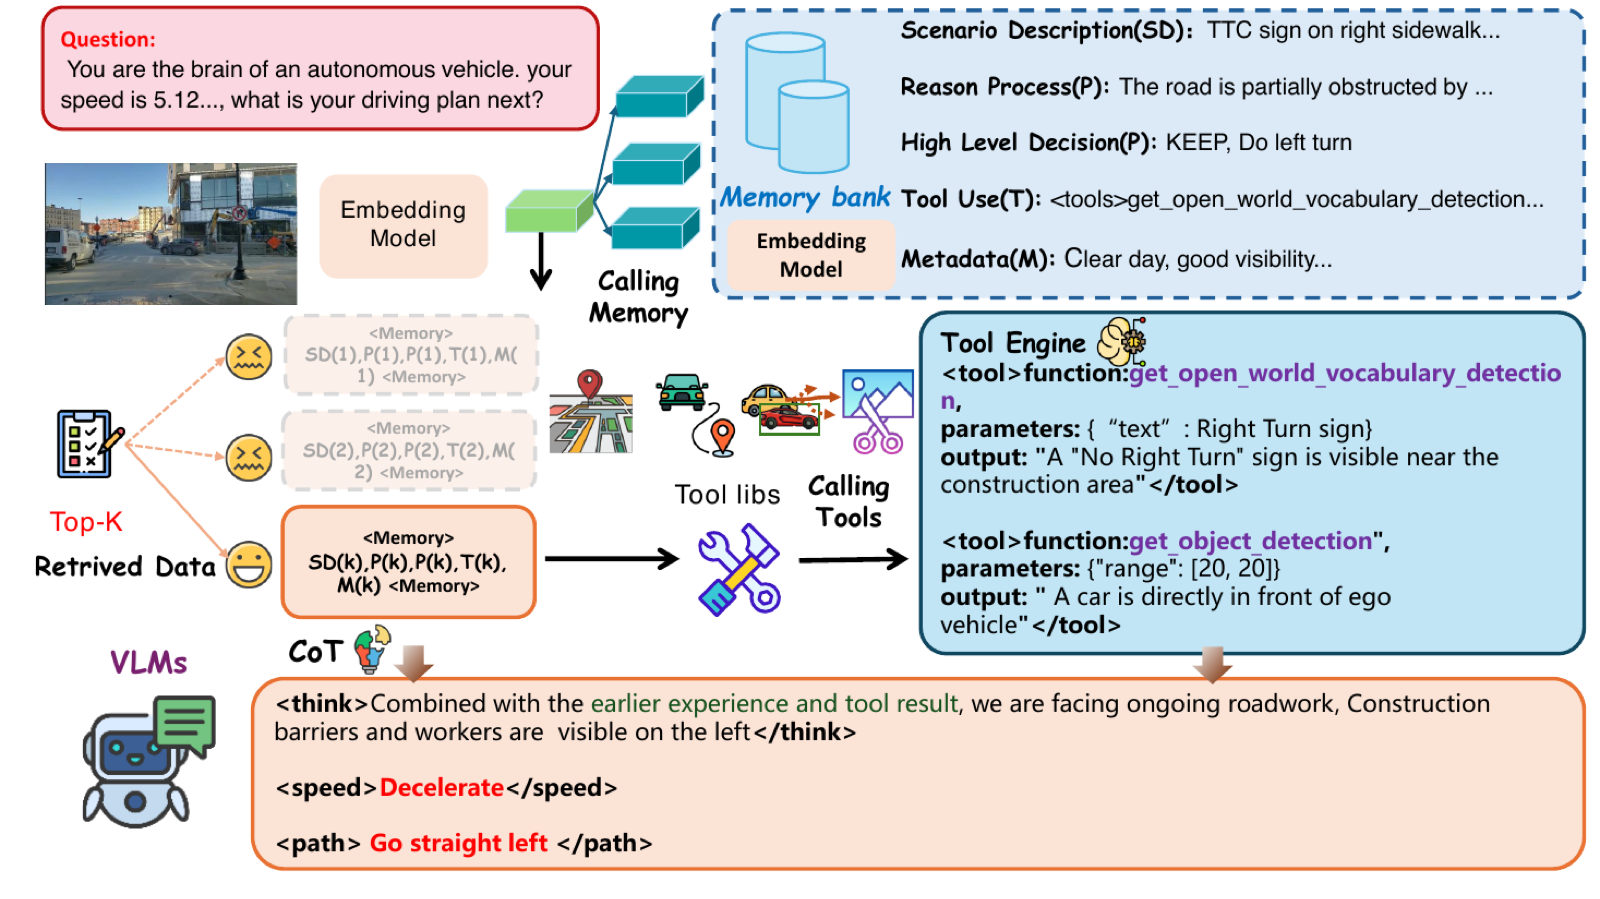 ICRA 2026
CCF B
Memory · Tool Use · Corner Cases
MTRDrive: Memory-Tool Synergistic Reasoning for Robust Autonomous Driving in Corner Cases
MTRDrive combines procedural memory retrieval with dynamic tools to improve robust reasoning in unseen construction scenarios.
 AAAI 2026
CCF A
Adversarial Training · Long-Tail Robustness
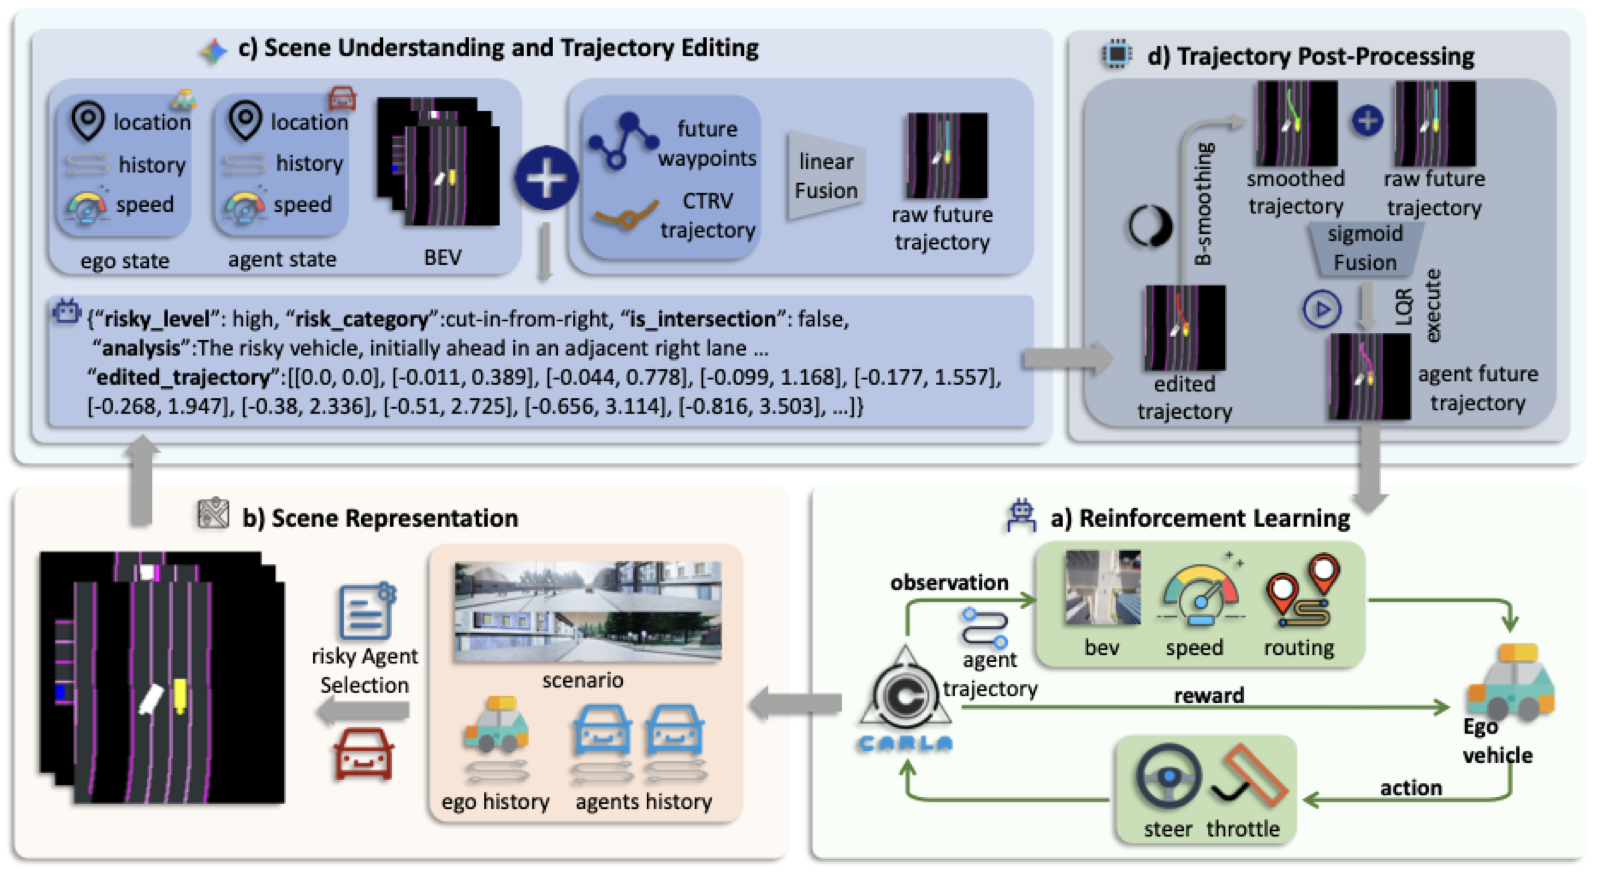
VILTA: A VLM-in-the-Loop Adversary for Enhancing Driving Policy Robustness
VILTA places a VLM adversary inside closed-loop training to generate challenging yet plausible agent trajectories.